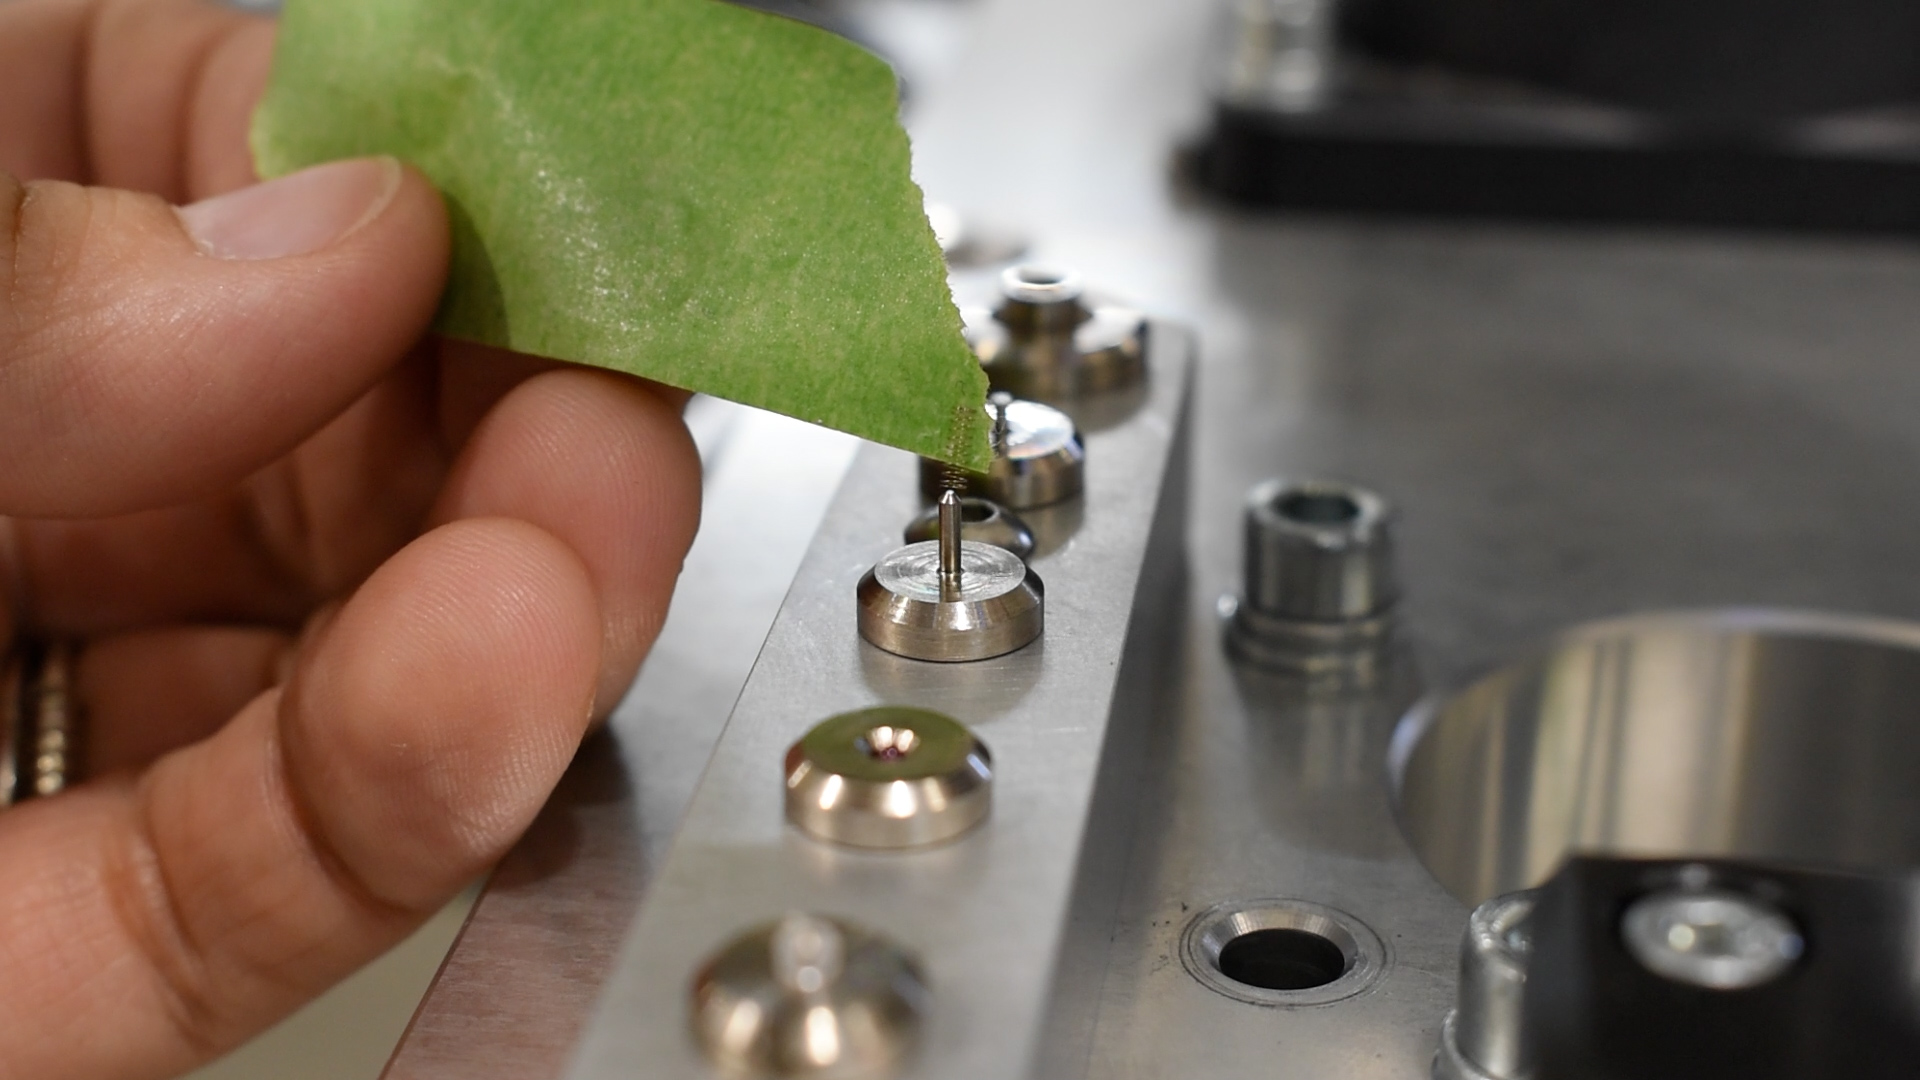
A compact robotic assembly cell can assemble parts as small as a 1.5 mm ruby ball, and a small part assembly proof of concept is the lowest-risk way to prove it before investing in a full production machine. A new customer in the analytical instrument manufacturing industry came to SDC with a check valve used in scientific instruments. Its ruby ball and plunger are each about 1.5 mm in diameter, and its spring is 4.2 mm long, wound from 0.06 mm wire.
Every valve was assembled by hand, and past trials had shown how hard these parts are to grip consistently. The customer asked SDC to prove that the most difficult part of the valve, a six-part stack-up of housing, plunger, spring, ruby ball, ball seat, and packing, could be built automatically.
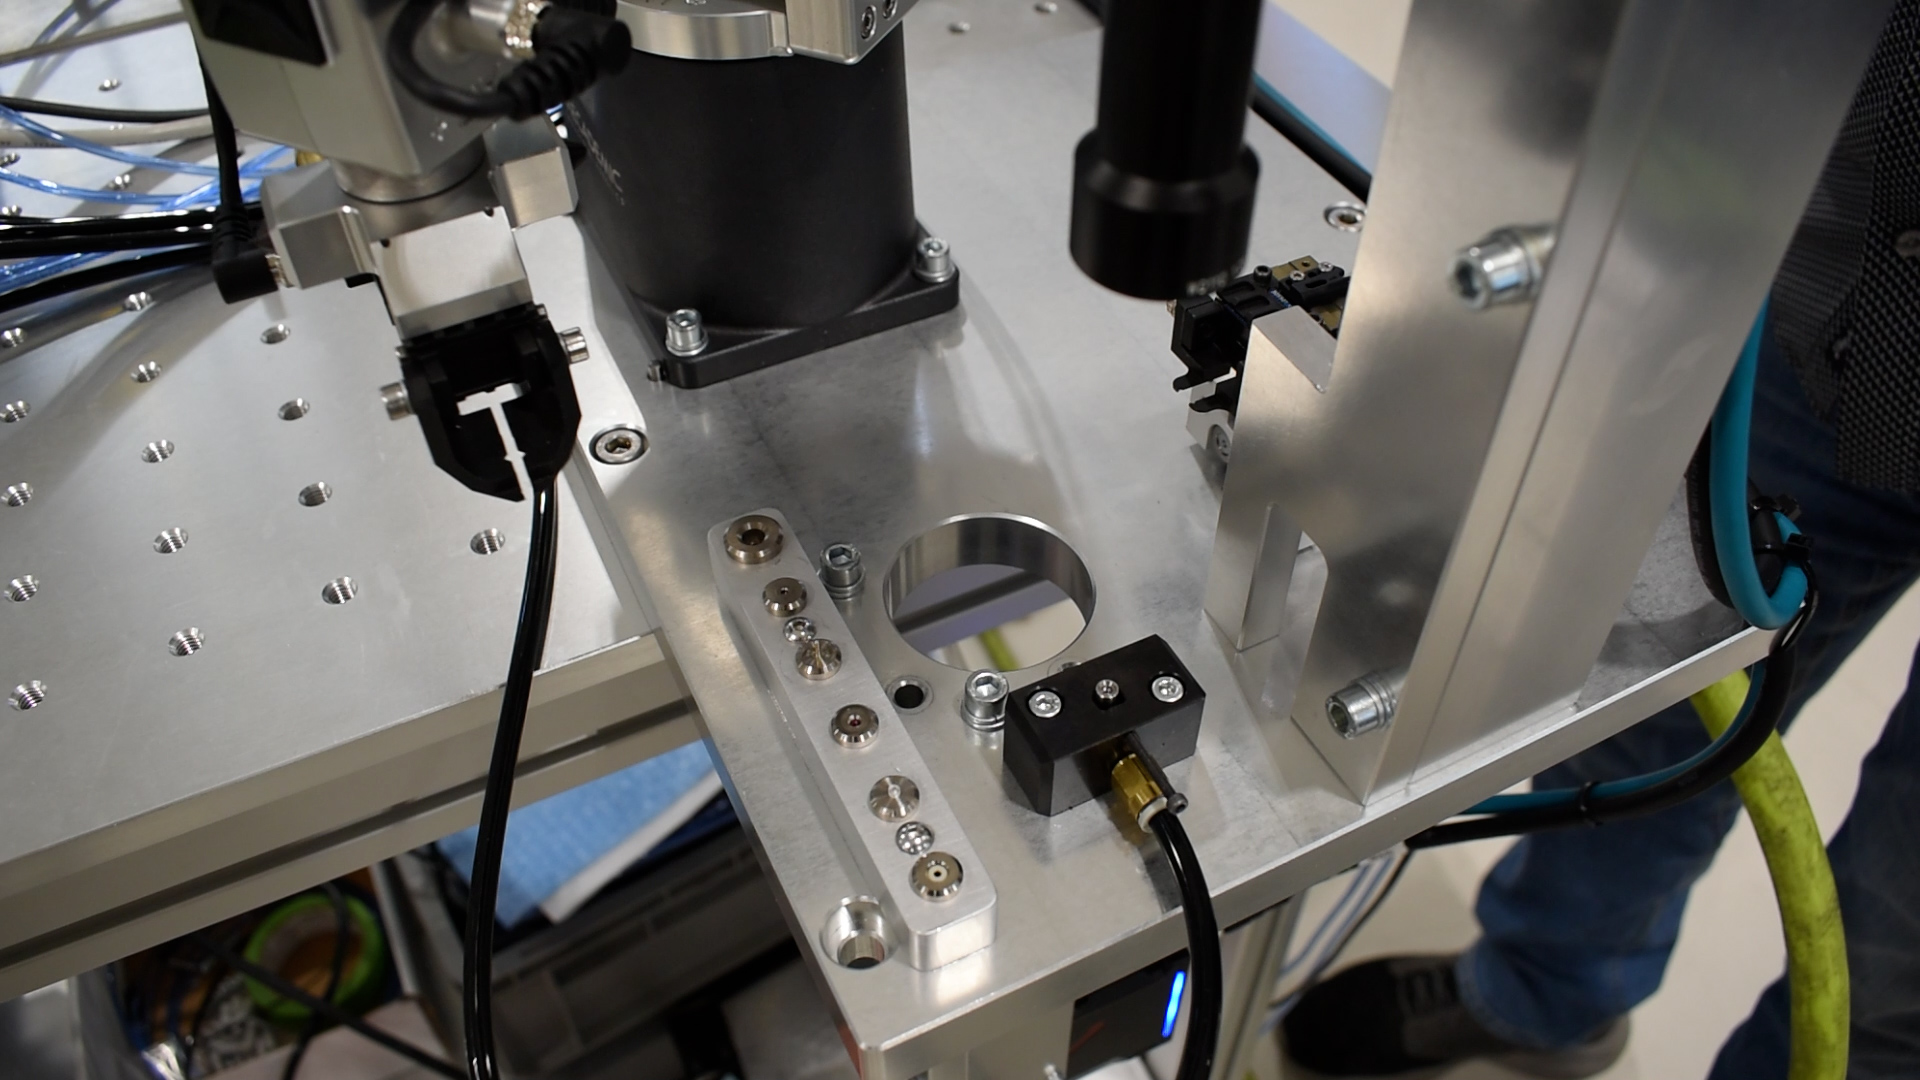
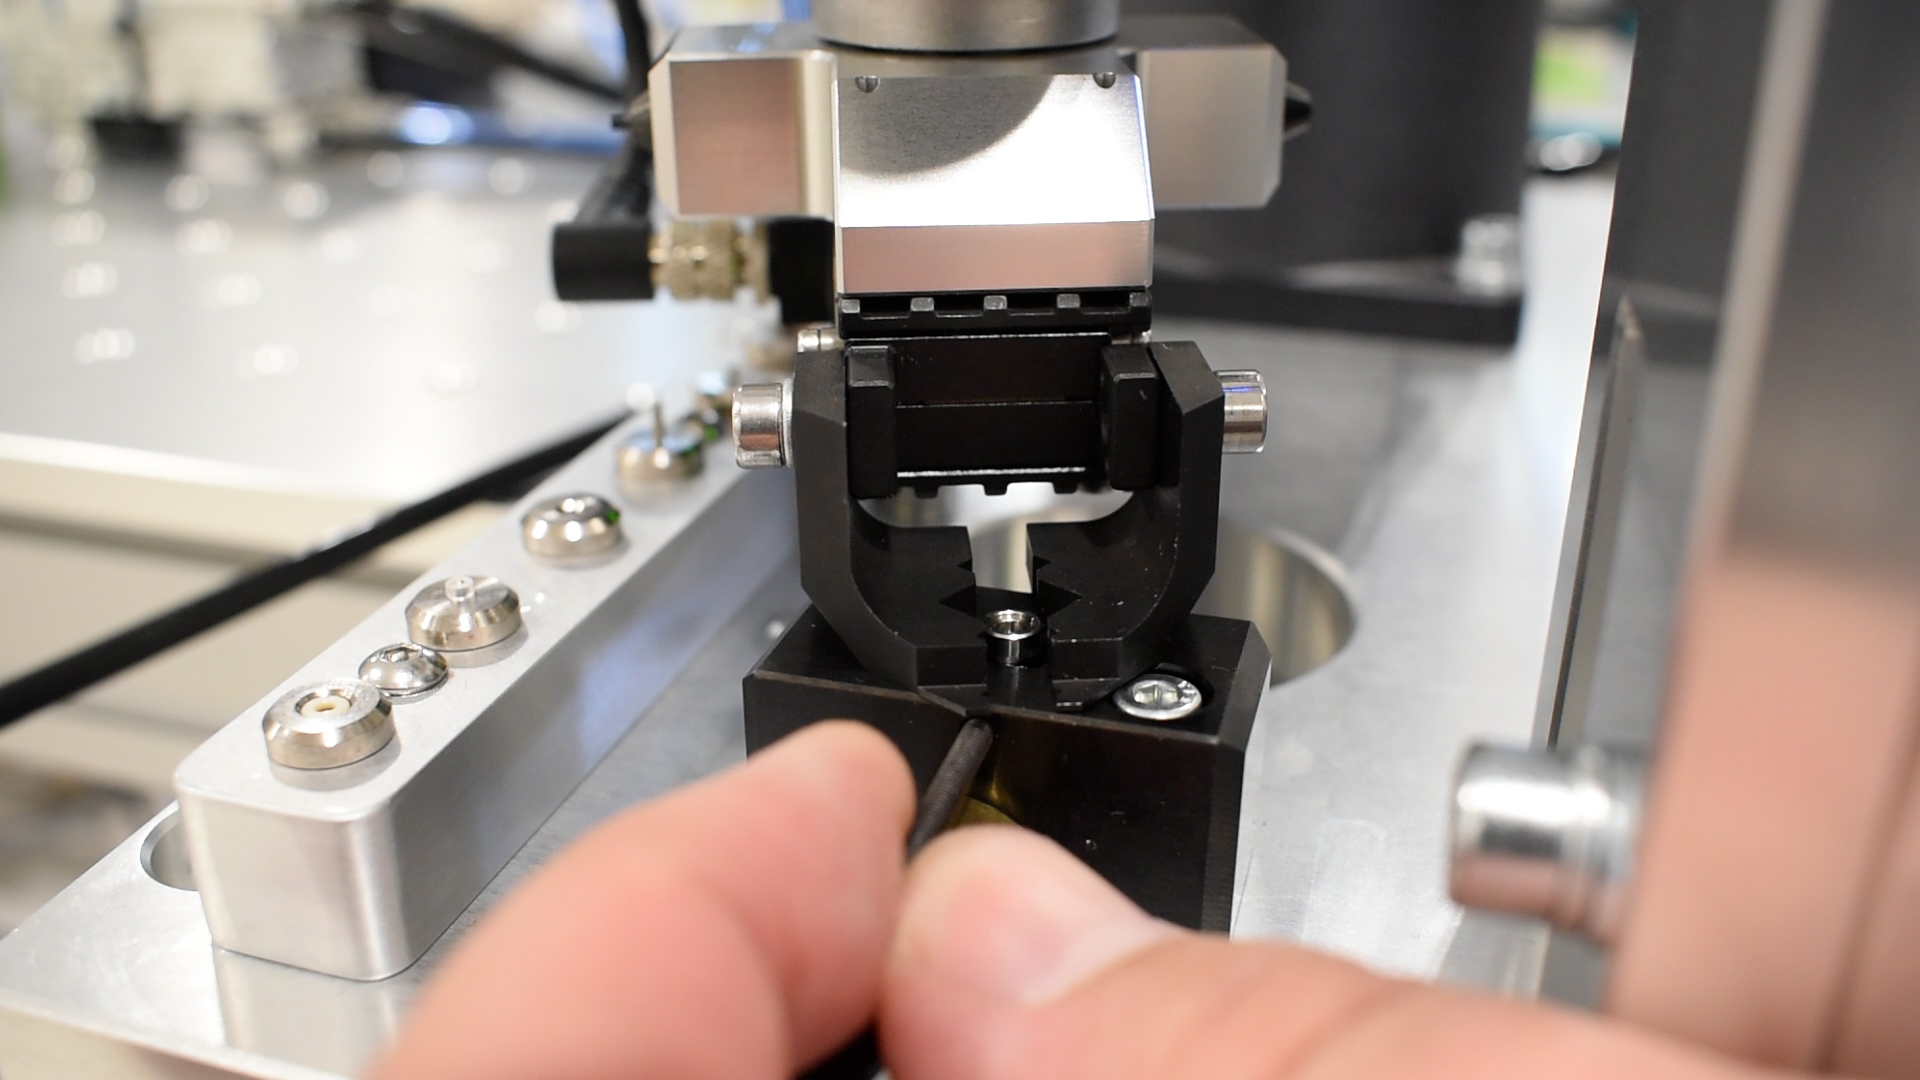
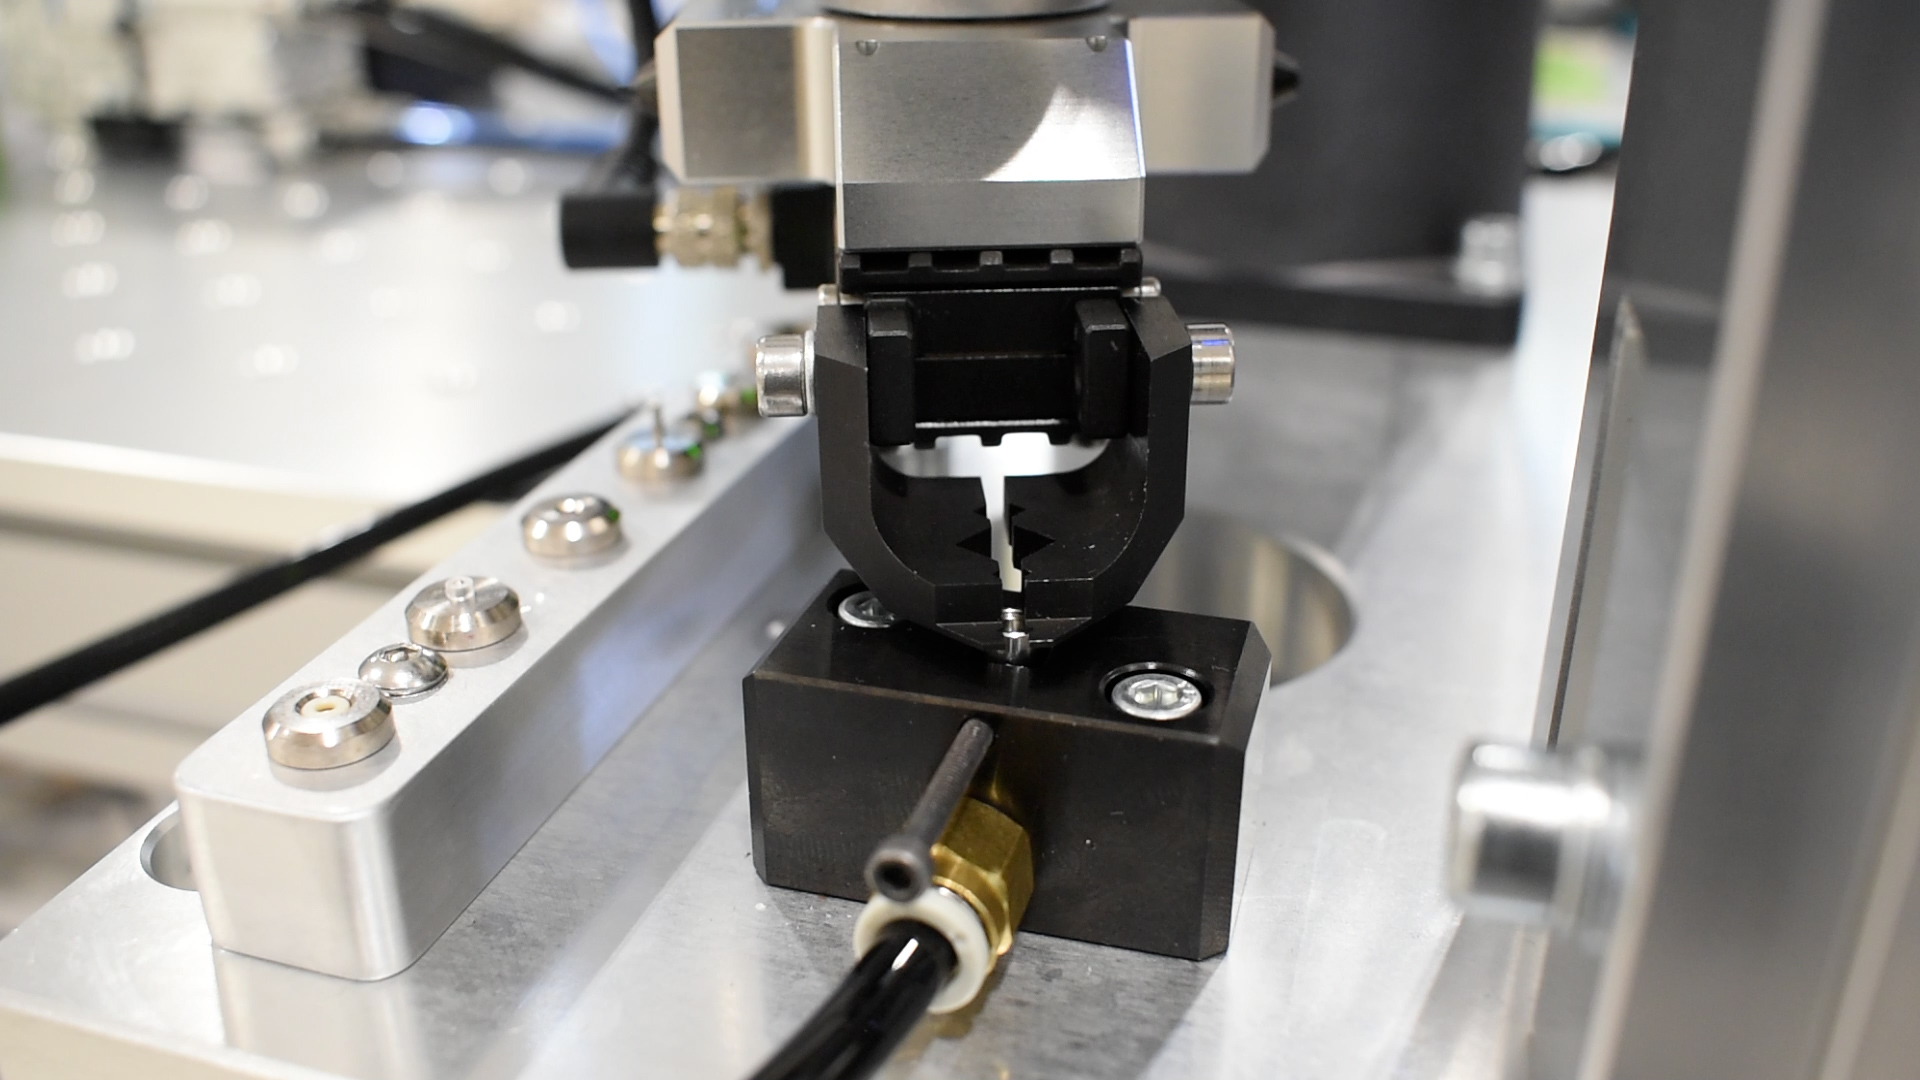
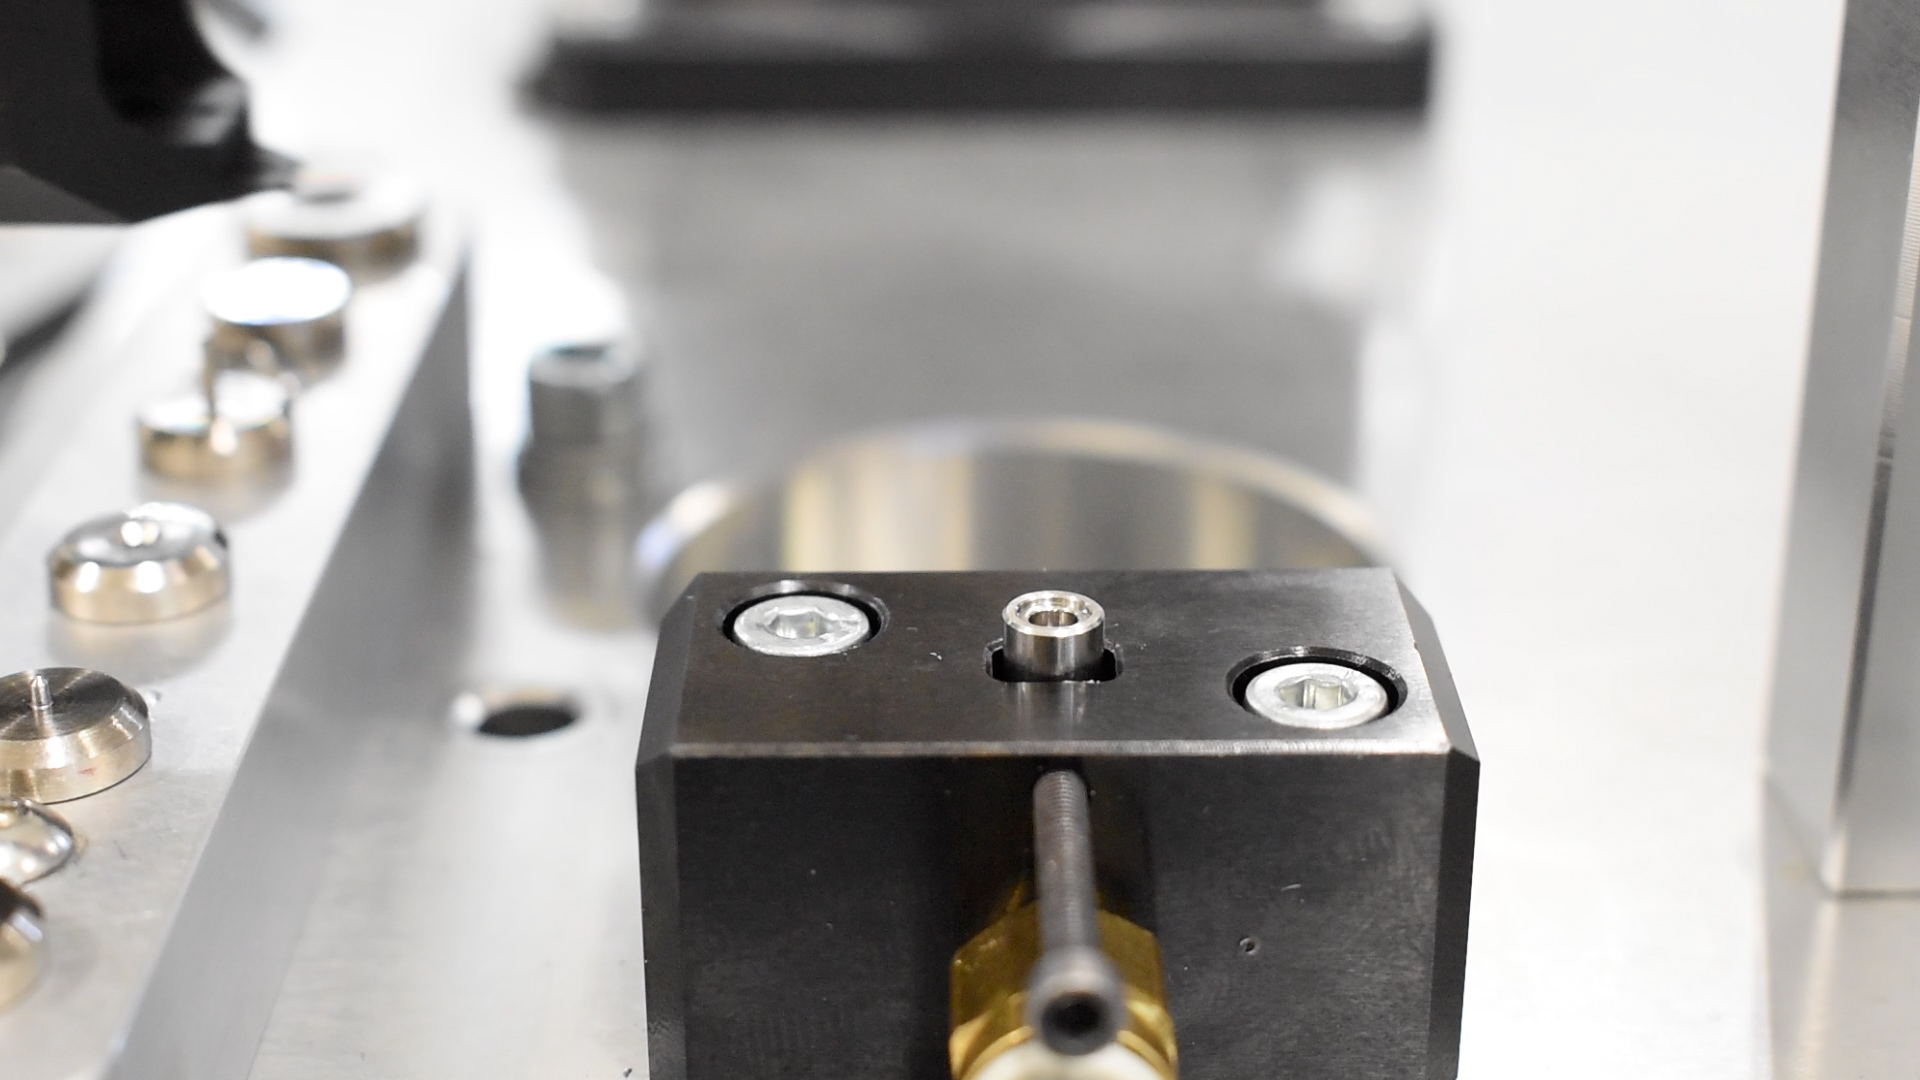
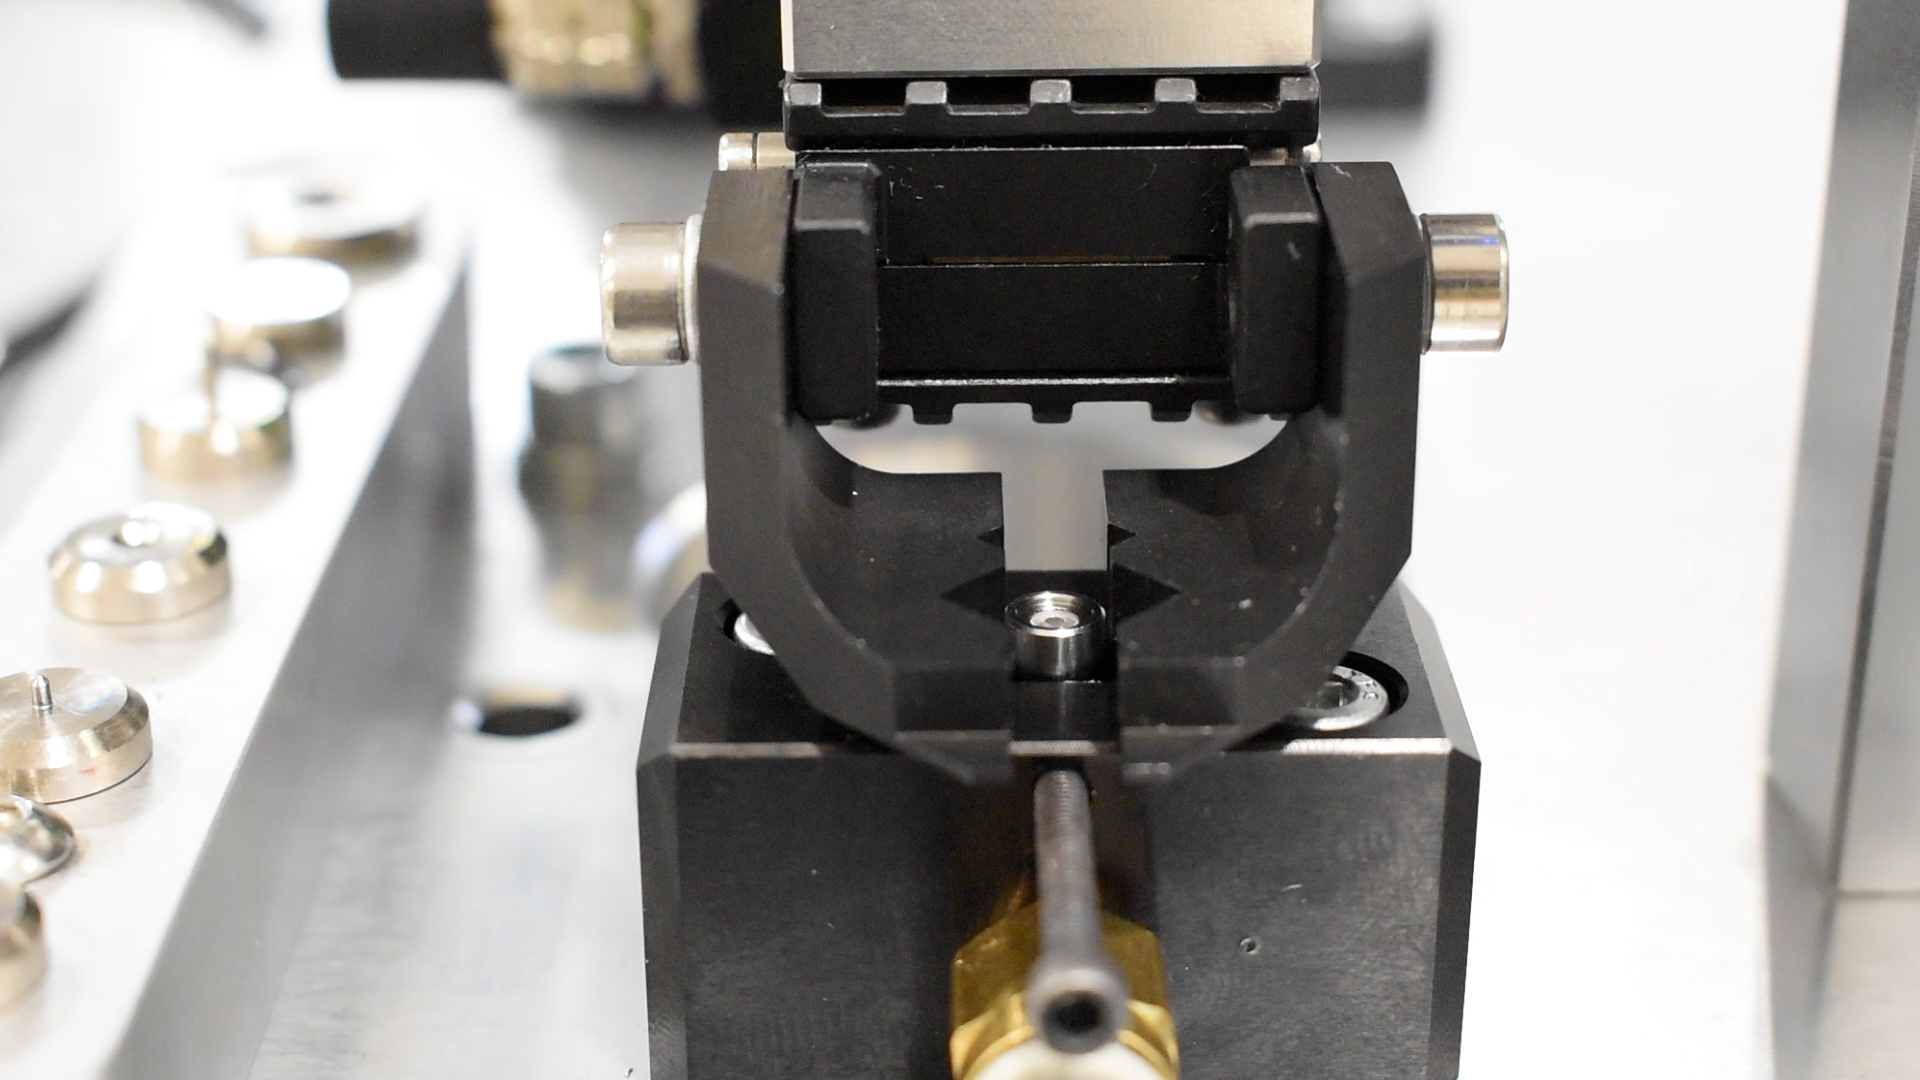
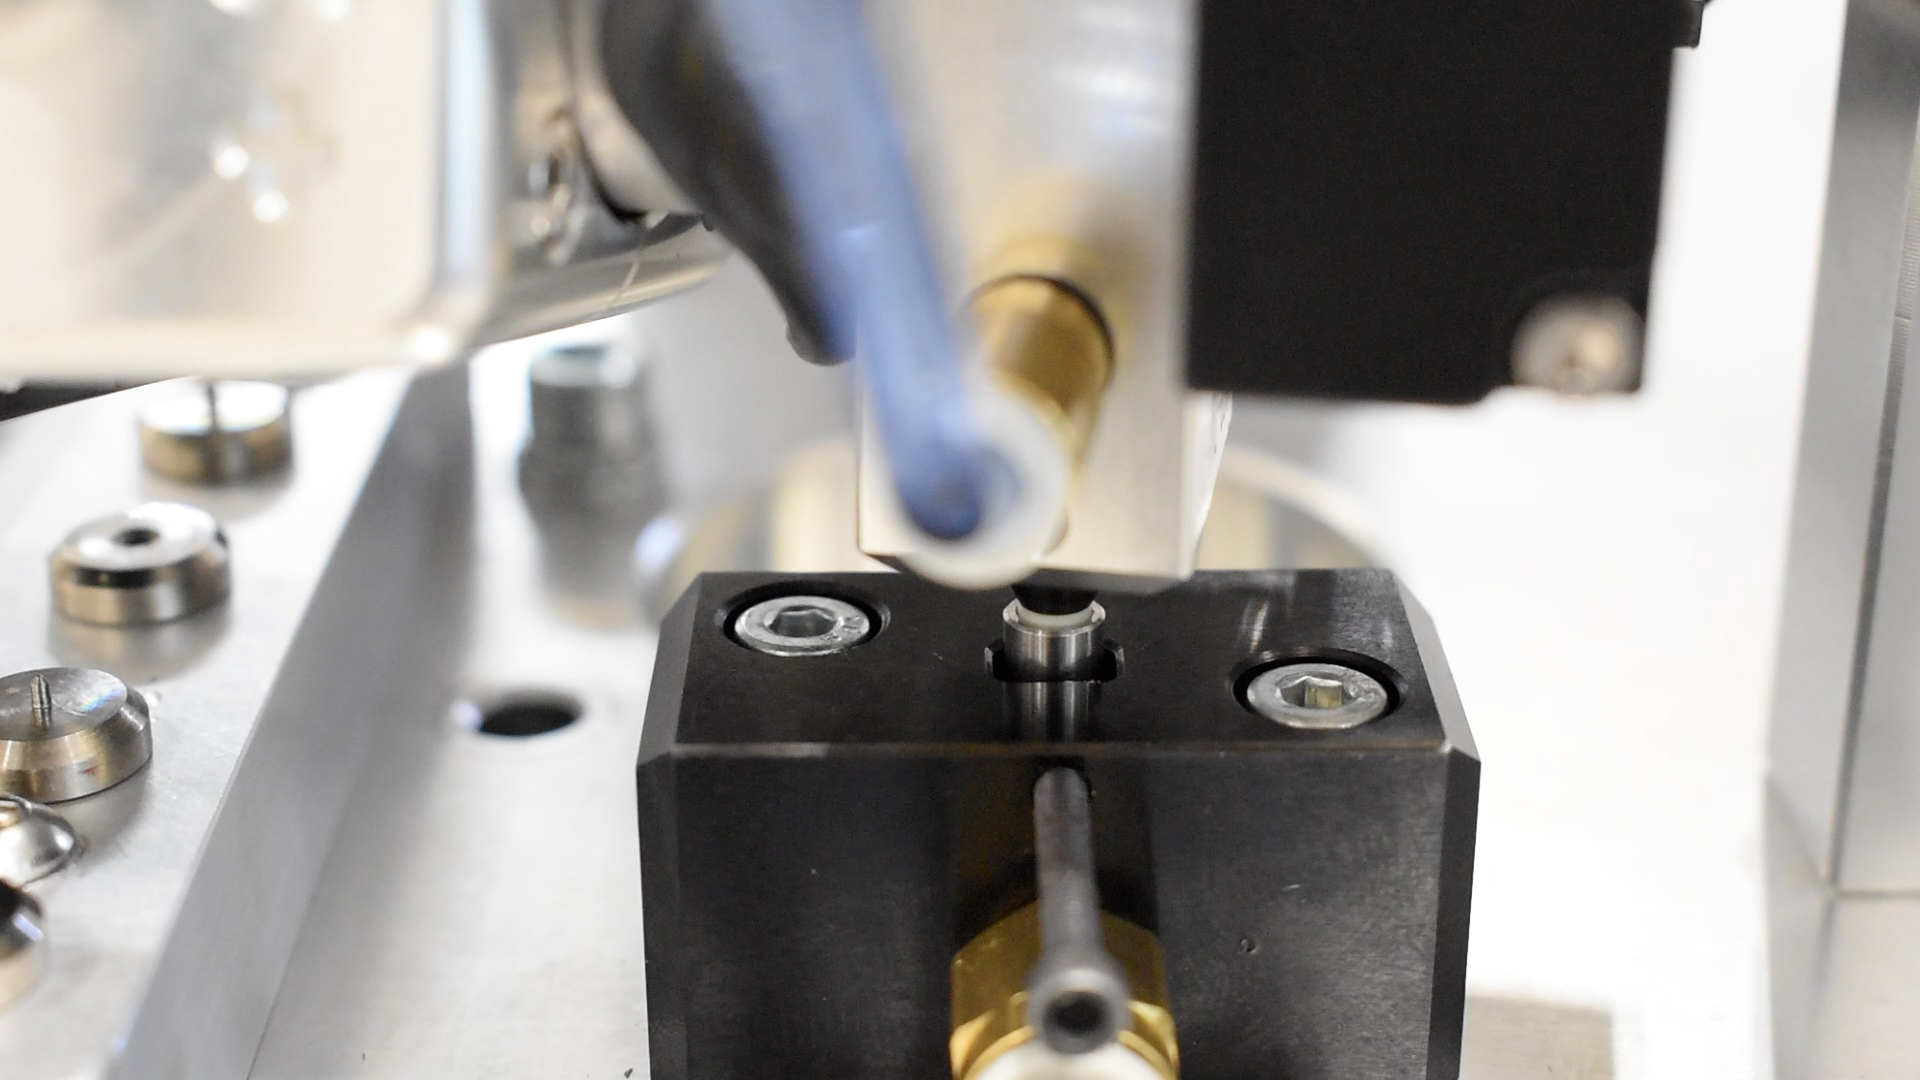
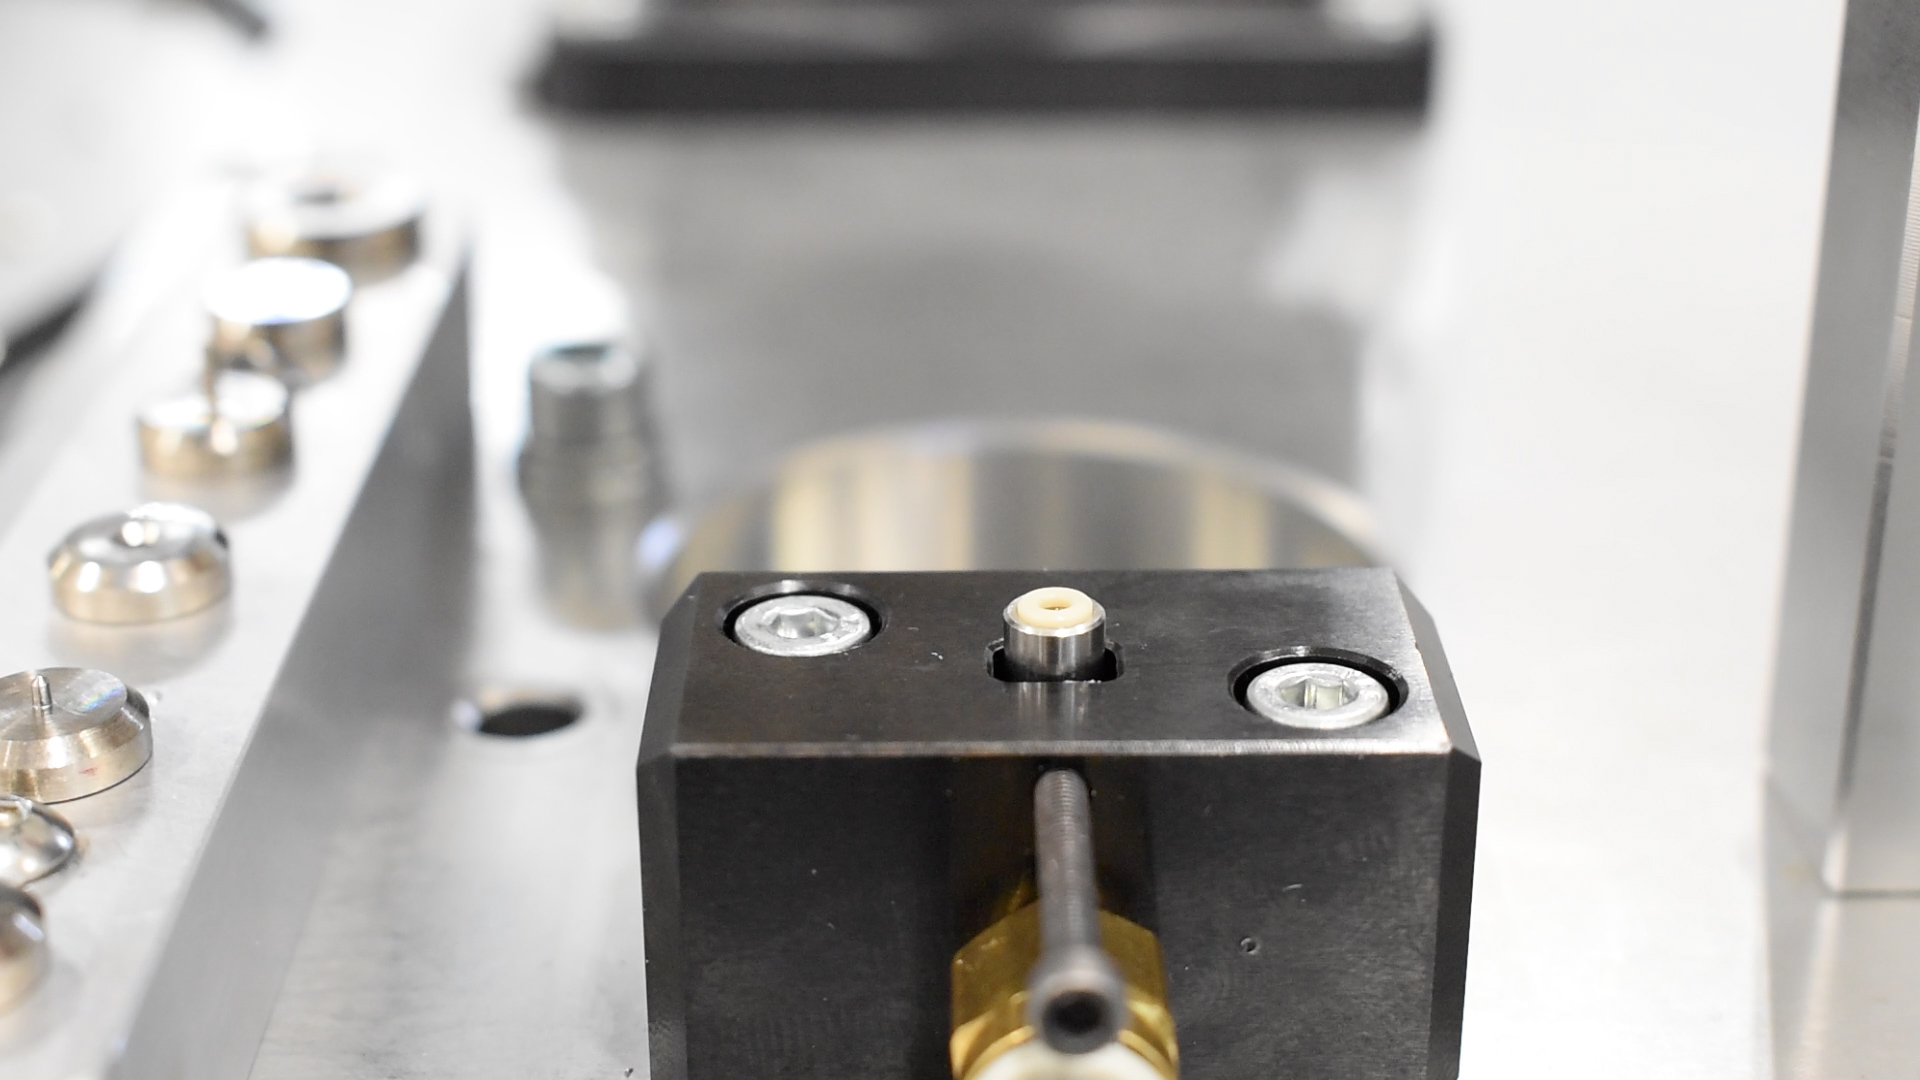
Instead of designing a full machine up front, SDC built a compact proof of concept cell around the hardest part of the valve. The cell had one job: show that six tiny parts could be picked, oriented, and stacked in the right order without a human hand.
The proof of concept stopped once the final part was placed. Pressing, greasing, and torque happen later in the customer’s process, so they were left for the full production machine.
SDC started by breaking down the customer’s manual process step by step, confirming part orientation and stacking order with the customer in writing. That became the foundation for a fixture and robot program built around a Mecademic robot.
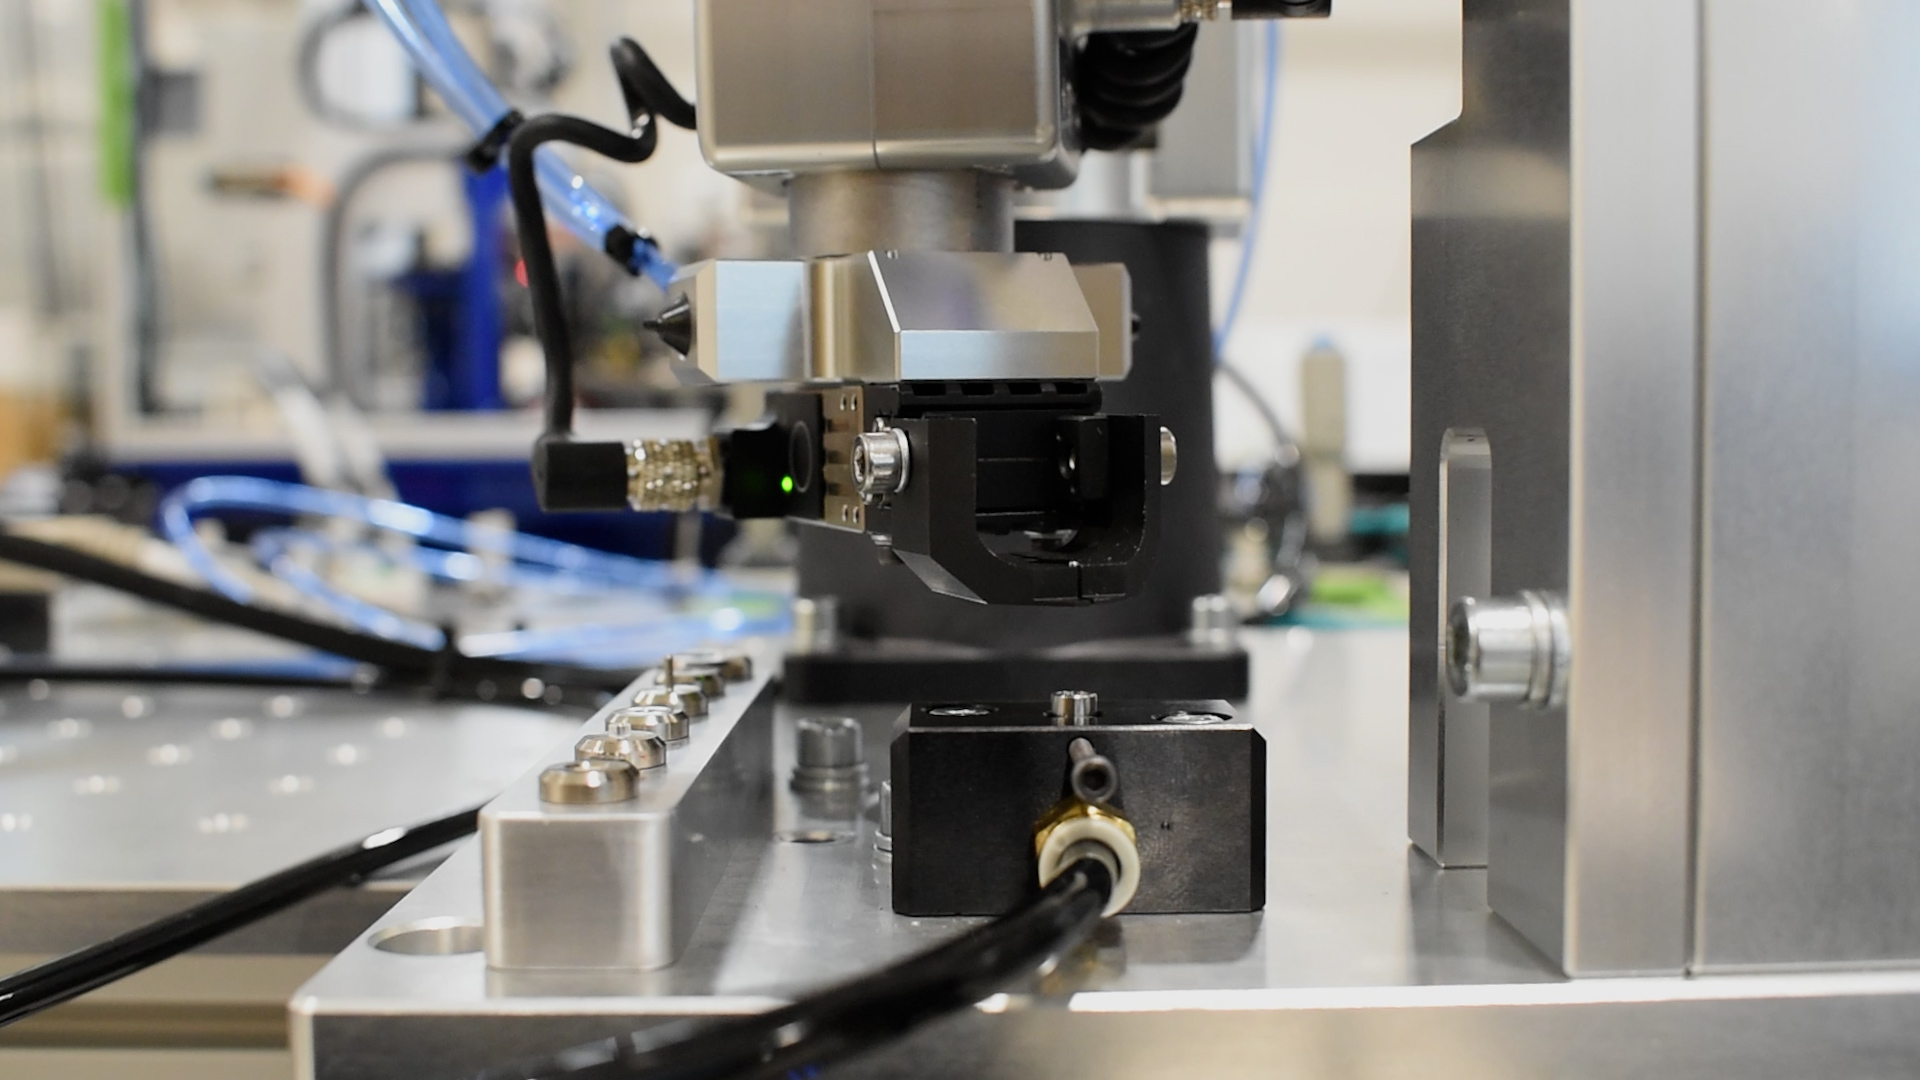
Parts this small needed more than one gripping method. SDC designed a single tool block that pairs a Mecademic electric gripper with two vacuum tools. The gripper handles the housing, plunger, spring, and ball seat, where orientation matters. The vacuum tools pick the ruby ball and soft packing without deforming them.
The spring was the toughest part. Vacuum couldn’t control its orientation, so the gripper holds it with gentle, adjustable force instead. At a hand-off station, a second gripper drops the plunger into the spring, and the robot moves the pair into the housing. During setup, magnified live camera views helped engineers line up each move.
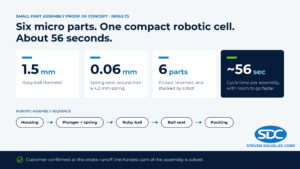
This project shows what SDC brings to micro precision assembly: careful process analysis, custom gripping tools, and precise fixturing built around each part. In a compact cell, a six-axis robot stacked six tiny parts, including a spring wound from 0.06 mm wire, in about 56 seconds. The customer confirmed it solved the hardest step in their process. For manufacturers wondering if their smallest parts can be automated, a small part assembly proof of concept turns an open question into a proven path to a custom automated assembly machine.
A: It is a focused test that shows whether tiny parts can be assembled automatically before a manufacturer invests in a full machine. It builds only the riskiest part of the process. This gives the manufacturer real data on handling, cycle time, and feasibility.
A: With the right robot, tooling, and fixturing, very small. In this project, SDC’s cell, built around a Mecademic Meca500 robot, handled a 1.5 mm ruby ball and a spring wound from 0.06 mm wire. The key is matching each part to the right gripping method and presenting it in a precise, fixed location.
A: It depends on the part. Vacuum works well for round, light, or soft parts like a ruby ball or packing. Parts whose orientation matters, like a tiny spring, need mechanical fingers with gentle, adjustable grip force.
A: Tiny parts are light, easy to deform, and hard to keep oriented. In this project, the spring couldn’t be held by vacuum, the packing was soft, and each ruby ball and seat came as a matched pair. Each part needed its own handling method and its own holder.